Robot cameras fall into four groups with different optical priorities. Humanoids and cobots need many small cameras. Mobile robots and drones need wide, rugged, consistent surround views, and drones add a weight budget. Industrial automation needs sharpness in a compact M12 format, and our catalog stops short of zoom, telecentric and metrology-class work. Depth sensing needs fast, NIR-coated, closely matched lenses. Most programs start with a catalog lens and move to custom only when field of view, size, wavelength or matching demands it.
A Robot is a Camera with a Plan
The plan can be a humanoid folding laundry, a warehouse robot threading between pallets, a cell inspecting a connector, or a depth module that other companies build into their own machines. In every case the camera is only as good as the lens in front of the sensor, and the lens that works in one of those places is often wrong for the next.
Humanoids & Cobots
Mobile Robots & Drones
Industrial Automation & Machine Vision
Depth Sensing Technologies
This article covers four robotics markets, each with different optical priorities: Humanoids & Cobots, Mobile Robots & Drones, Industrial Automation & Machine Vision, and Depth Sensing Technologies. It walks through what each one asks of a lens, which Sunex lens families tend to fit, and where a program should move from an off-the-shelf lens to a custom design.
Read this first: the lenses named here are examples, not recommendations
Lens part numbers in this article show the kind of product that fits each situation. Your sensor, mounting, environment and verification needs decide the right choice, and our engineers will confirm it against the current datasheet.
Why does almost every robotics camera program start in the same place?
Robot programs move fast. Hardware revisions arrive every few months, and the camera team usually needs real images before the mechanical design is frozen. That makes the off-the-shelf lens the natural first step, followed by custom design only if the numbers demand it.
The off-the-shelf portfolio
We catalog hundreds of miniature M12 lenses, grouped by what a robot needs: ultra-wide and fisheye lenses for surround perception, low-distortion wide lenses for forward navigation, NIR-optimized lenses for depth sensing, ruggedized and sealed lenses for harsh floors and weather, and fast higher-resolution lenses for compact cameras. Many fisheye parts are built to automotive-grade reliability. Holders and thread adapters make the lenses easy to drop onto a camera board.
30+ years of custom design
When no catalog lens fits, we design one. For robotics that usually means a distortion profile tuned to keep resolution at the edge of an ultra-wide image, a coating matched to a specific emitter wavelength, a change in size or thread, or a matched set for stereo pairs.
Three numbers to check on any datasheet
Three numbers on the datasheet decide most first selections. The image circle has to cover your sensor’s diagonal, or the corners go dark. The field of view is quoted at a stated image circle, so the angle you get on a smaller sensor is narrower than the headline figure. And the f-number sets how much light reaches the pixels, which matters most with global-shutter sensors running short exposures. Check all three against your sensor before you order samples. It takes ten minutes.
Table 1: Off-the-shelf vs. custom lens for robotics
| Criterion | Off-the-shelf | Custom design |
|---|---|---|
| Time to first images | Days to weeks | Months [CONFIRM] |
| Upfront cost | Low | Design and tooling investment |
| Optical fit | Closest catalog match | Tuned to sensor and software |
| Mechanical fit | Standard M12 and adapters | Size, thread and mount changes |
| Unit cost at volume | Catalog pricing | Depends on volume [CONFIRM] |
| Best use | Prototypes and many production programs | When no catalog lens meets a requirement |
VERIFICATION STILL APPLIES
A catalog lens shortens the first prototype. It does not remove your own validation: field of view on your sensor, distortion model, focus over temperature, and behavior in the real environment all need testing on your camera.
What does a robot need to see when it works beside people?
The imaging challenge
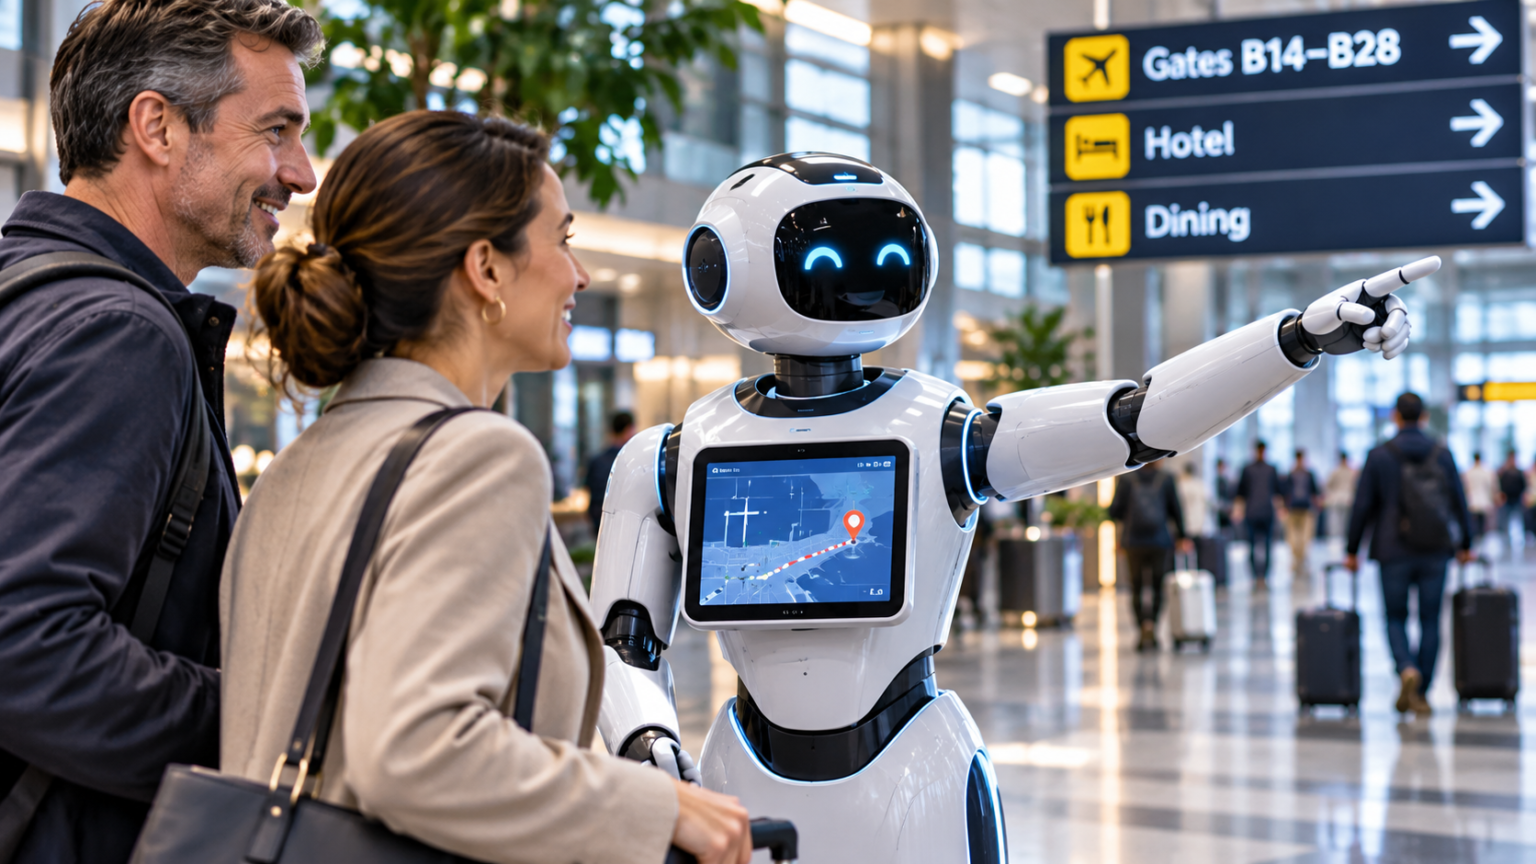
Humanoids and collaborative robots share a job: working next to people on tasks. A humanoid may carry six cameras or more, with published designs ranging from about six to as many as twelve. A cobot arm usually needs one or two. Those cameras do different jobs: wide views for navigation and obstacle avoidance, finer imaging at the hand or wrist, and a head or torso depth module for reaching and grasping.
The constraints are size, weight and fast design cycles. A camera on a wrist or a finger-sized head has almost no room, and humanoid makers revise designs quickly. Global-shutter sensors are common because the robot moves, and NIR sensing is common because depth drives manipulation.
Calibration is the hidden cost. Every camera on a humanoid is calibrated against the others, and a head or wrist that flexes or warms up shifts that calibration. A lens that holds focus over temperature reduces how often the robot has to recalibrate itself. If you are choosing between two lenses with similar fields of view, ask which one moves less when the head electronics heat up.
Lens examples
- Torso and surround: ultra-wide M12 lenses such as the DSL188A and the DSL180 family. Both are F/2.0 lenses with tailored distortion. The DSL188A is listed at 204° on its full 4.0 mm image circle for 1/4-inch sensors, and the DSL180 at 200° on a 3.8 mm image circle.
- Wrist and hand: low-distortion wide lenses from the DSL958 family and similar parts: 4.6 mm focal length, F/1.7, all-glass, with a 76° field on a 6.0 mm image circle for sensors up to 1/3 inch. The DSL958E version has an M10 thread where a wrist has no room for M12.
- Head depth module: fast NIR lenses such as the TOF versions of the DSL146A and DSL147A. Both are F/1.4 lenses for sensors up to 1/2.8 inch with an 800 to 1000 nm anti-reflection coating. On a 1/2.8-inch sensor the DSL146A gives about 94° horizontal and the DSL147A about 122°.
Where custom design takes over
A smaller barrel for a finger-width wrist, a tailored distortion profile that gives the head both coverage and forward detail, or a two-channel single-sensor design for close-range stereo.
Autofocus is a mature technology, and we have integrated autofocus technologies from several different vendors. A hand camera that works from a few centimeters out to arm’s length is the obvious case for it. We expect autofocus to play a role in robotics moving forward.
CUSTOMER SCENARIO
A humanoid developer has a head module, a torso surround ring and two wrist cameras, each from a different supplier, and every revision changes the mounting. Question to ask: which of those cameras can share one lens family, and which need a custom variant so that the design survives the next revision?
WHERE A SUNEX LENS IS NOT THE RIGHT FIT (YET)
Programs that need high-end metrology or fine-resolution inspection from a wrist camera may exceed what a miniature M12 lens delivers. Talk to us early so we can say so.
How do robots that drive or fly keep seeing where they are going?
The imaging challenge
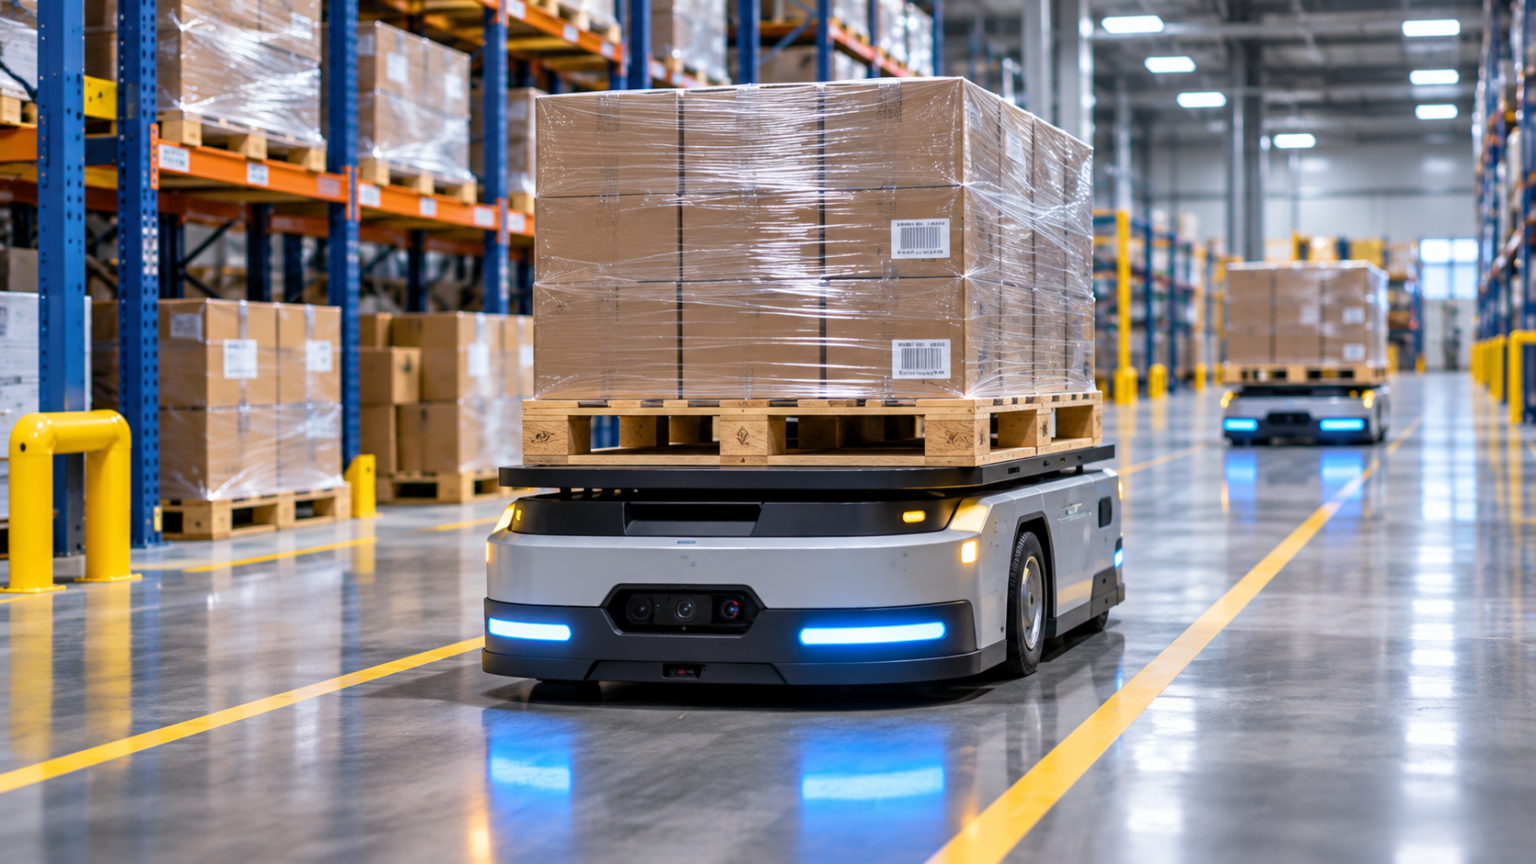
Mobile robots move goods, inspect and patrol: warehouse AMRs and AGVs, goods-to-person systems, sidewalk and last-mile delivery, hospital and hospitality service robots, inspection and patrol platforms, and, as a smaller group, consumer home robots. A robot that moves needs to see around itself, so surround perception is the core requirement. A warehouse robot often carries around three cameras, and service robots carry two to four sensors.
Mobile robots also live in the worst conditions: dust, washdown, vibration, glare and impact. A camera that is clean on day one may be scratched or fogged by month six, which shows up as lost tracking rather than an obvious fault. Visual SLAM adds its own requirement: a wide field of view and a global shutter, so the robot can track its position while it moves.
Lighting is the other variable. Warehouse aisles are often dim, and some facilities run with the lights off, so many mobile robots pair their cameras with NIR illumination. The fisheye families in the examples below all come in NIR versions with no IR-cut filter for that reason. The trade is color: without an IR-cut filter, daylight color looks washed out, so a robot that needs both usually carries separate cameras.
What changes when the robot flies
Drones are mobile robots with a weight budget. They inspect power lines and bridges, map sites, count inventory in high-bay warehouses and deliver small parcels. Navigation follows the same pattern as on the ground, a ring of wide cameras for surround perception, but the ring now has to cover above and below as well. One widely published design uses six 4K navigation cameras, each behind a 200° fisheye lens. Other platforms combine fisheye cameras with LiDAR, radar and a downward time-of-flight sensor.
Three things get harder in the air. Every gram of lens costs flight time, so barrel material and element count get a level of scrutiny they rarely see on a warehouse robot. Propeller vibration skews and smears images, which pushes navigation cameras toward global-shutter sensors or short exposures, and so toward fast lenses. And a drone looks at the sun and sky far more often than a floor robot does. Ghosting and stray light from a bright source at the edge of the frame can look like an obstacle, or hide one.
The payload camera is a different product. Mapping and inspection payloads usually call for low distortion, high resolution and often zoom on a stabilized gimbal. Our catalog has no zoom lenses. We are a fit for the navigation cameras and for fixed-focal-length payloads, not for zoom gimbals.
Lens examples
- Surround perception: ultra-wide and fisheye lenses such as the DSL188A, DSL180 and DSL367B. At the full image circle they are listed at 204°, 200° and 210°. The DSL188A and DSL367B are built for 1/4-inch sensors, the size class of common global-shutter tracking sensors such as the OV9282, and the DSL367B datasheet gives 190° at a 3.84 mm image circle. Tailored distortion keeps usable pixels at the edge.
- Forward navigation: low-distortion wide lenses such as the DSL958 family, described for forward machine vision. The datasheet lists a 76° field at a 6.0 mm image circle and 17% rectilinear distortion.
- Drone navigation: the same superfisheye families apply. The DSL188A and DSL367B pair a field of 200° or more with hybrid construction and 120 dB HDR on 1/4-inch sensors, which helps when the sun is in the frame. For navigation sensors in the 1/2.8-inch class, the DSL147A covers up to 8 MP at F/1.4, but it is a larger all glass and metal lens, so check it against the weight budget.
- Dust and washdown: the DSL958R carries an IP6K9K front seal. Sealed-first-element fisheyes such as the DSL182 (194° at a 5.4 mm image circle, F/2.2, sensors up to 1/1.8 inch) suit outdoor and washdown use, and one version adds our HP3 hydrophobic coating.
Where custom design takes over
Consistent distortion across a ring of cameras for stitching, a barrel that fits a bumper or mast, or protection for outdoor robots. Our environmental protection technologies, including scratch-resistant and water-shedding front surfaces and lens heating, address the front lens surface where most field failures start. See our Environmental Protection Technologies article.
For drones, custom work is usually about weight and weather: a lighter barrel, a hybrid glass-plastic design in place of all-glass, and a water-shedding front surface so that rain beads off in the airflow.
CUSTOMER SCENARIO
A logistics robot maker ships a warehouse AMR with three cameras to a customer that orders 100 to 500 units at a time. Question to ask: do all three cameras use the same lens, and what happens to image quality after a year of dust, vibration and forklift traffic?
What does a camera on the production line actually need from its lens?
The imaging challenge
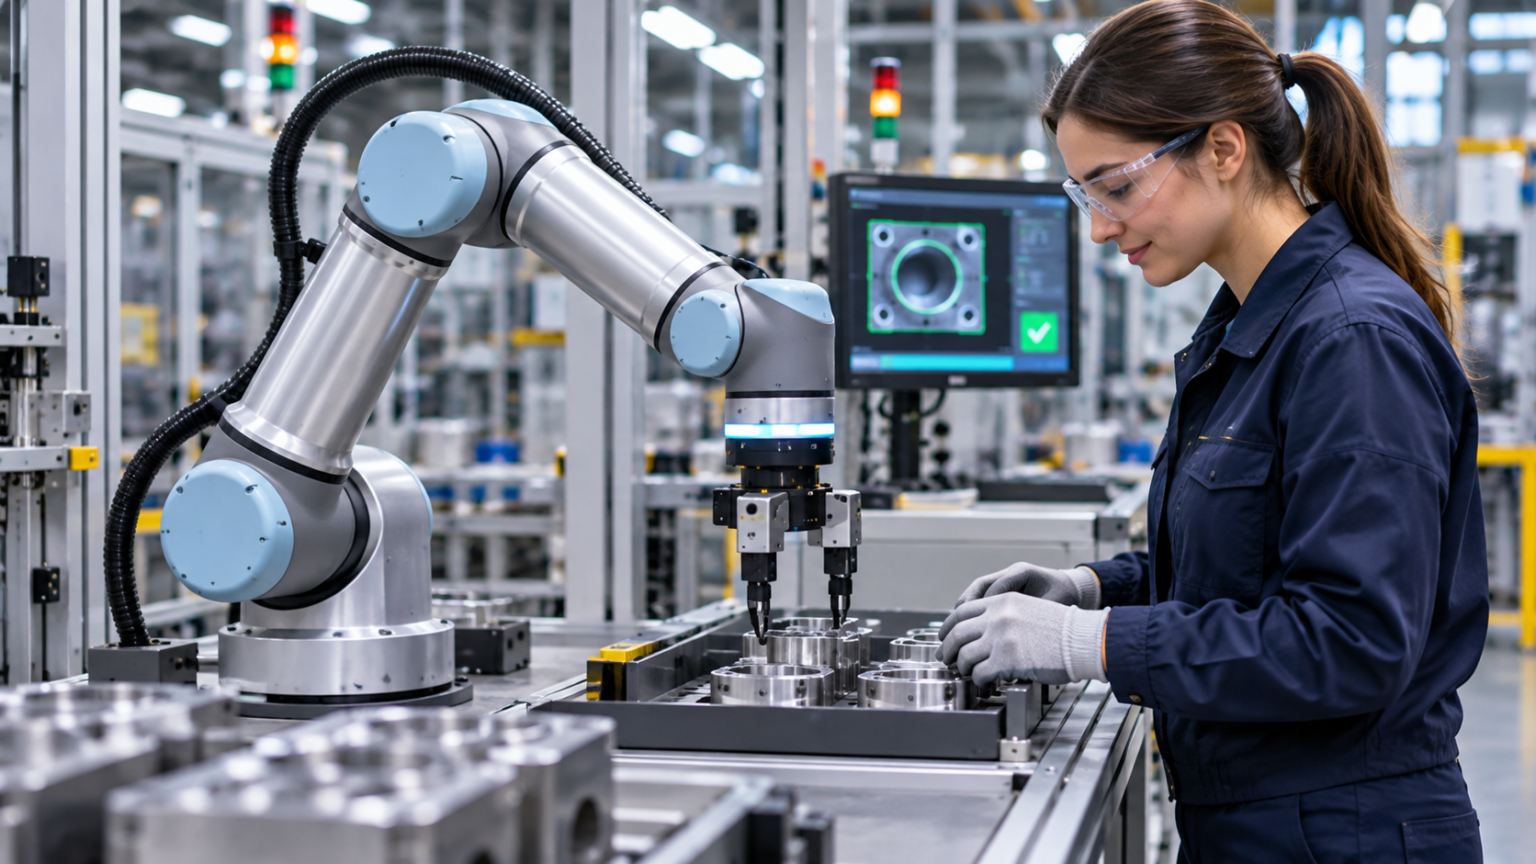
Industrial automation puts cameras on the production or handling line: caged industrial arms, pick-and-place and bin-picking cells, smart cameras (cameras with built-in image processing), inline inspection, and conveyor and packaging vision. The main jobs are recognition, inspection and guiding the arm, so detail matters more than coverage. A guided arm or cell usually needs one or two cameras.
The optical priorities are sharpness, a mid-width field, compact size and a rugged build for the factory floor. 3D vision is a growing share of vision-guided robotics, so NIR-ready lenses matter more each year.
Aperture is a real design choice here, not a default. A fast lens gathers more light, but depth of field shrinks, and a part that sits a few millimeters high on the conveyor goes soft. That is why the DSL958G is cataloged at F/1.7, F/2.8 and F/4.0. With strong, controlled lighting in a cell, the slower lens is often the better inspection lens.
Moving from C-mount to M12 is the other common question. M12 lenses are smaller, lighter and lower in cost, and they suit the small and mid-size sensors used in embedded cameras. The cost is adjustability: most M12 lenses have a fixed aperture and are focused once at assembly, then locked. If your process needs an operator to refocus or stop down on the line, stay with C-mount.
Lens examples
- Embedded and AGV cameras: the DSL958 family and the DSL137A, a machine vision lens described for robotic, environmentally challenging applications. The DSL137A is a 1.85 mm, F/2.35 all-glass lens for 1/4-inch sensors with a 179° field at its 3.9 mm image circle.
- Compact smart cameras: fast, higher-resolution lenses such as the DSL146A (3.3 mm) and DSL147A (2.5 mm), an F/1.4 family rated up to 8 MP (4K) for sensors up to 1/2.8 inch.
Where custom design takes over
Custom work here is usually a size, thread or coating change for a smart-camera design-in, or a wrist camera that must fit a specific arm.
CUSTOMER SCENARIO
A smart-camera maker is moving from a fixed-focus C-mount lens to an M12 lens to shrink the housing. Question to ask: what resolution does the inspection task need at the edge of the image, and does the new lens still meet it across the temperature range?
Why does the lens decide how good a depth sensor is?
The imaging challenge
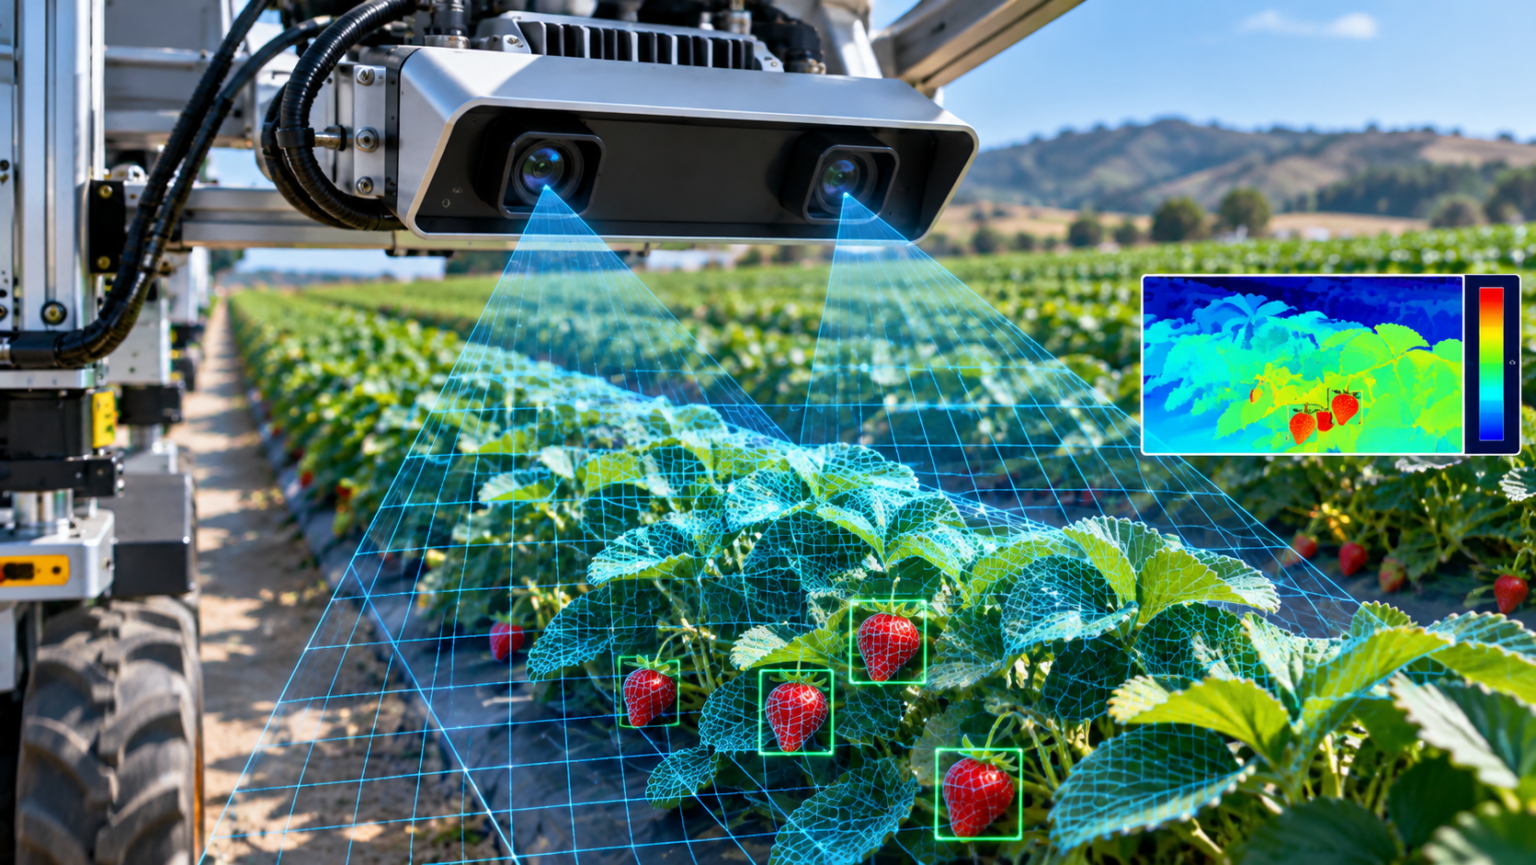
Depth sensing is a horizontal technology: stereo, time-of-flight, structured light and robotics LiDAR cut across every robot type, and the companies that build them sell into many verticals. Embodied-AI developers belong here too, because they buy cameras for development kits, data-collection rigs and their partners’ robots, and the application changes by customer. One win in this market reaches many robots.
The lens is part of the measuring instrument. It needs a coating matched to the emitter wavelength, a low f-number to collect light, stable focus over temperature, and tight lens-to-lens consistency so that the two halves of a stereo pair behave alike. A depth module typically holds two or three lenses: a stereo pair and sometimes an RGB camera.
Wavelength choice drives the rest. Most active depth systems run at 850 nm or 940 nm. Silicon sensors respond better at 850 nm, while 940 nm sits in a dip in the solar spectrum and holds up better outdoors. A bandpass filter matched to the emitter then blocks most of the remaining ambient light. Whichever you choose, tell us early, because coating and filter are specified together.
Matching matters because stereo depth is computed from small differences between two images. If the two lenses differ slightly in focal length or distortion, calibration can absorb it. It cannot absorb a difference that drifts with temperature or time.
Lens examples
- ToF and NIR depth: the DSL146A-NIR-F1.4-TOF has an 800 to 1000 nm anti-reflection coating at F/1.4, and BP940 versions of the DSL146A and DSL147A add a 940 nm bandpass filter option. NIR (no IR-cut) versions exist for most families.
- Fast, higher-resolution stereo: the F/1.4 DSL146A and DSL147A families, with about 94° and 122° horizontal on a 1/2.8-inch sensor.
- LiDAR receiver optics: the DSL143D-NIR-F1.4 is a 40.6 mm, F/1.4 receiver lens for 1.5-inch-format detectors with an advanced AR coating. It is a far larger lens than the M12 parts above.
Where custom design takes over
Depth modules are where custom design pays most: a wavelength-specific coating, a matched set, or a focus design tuned to a particular housing.
The emitter side is a separate question. We build fast projection lenses, such as the F/0.7 DSL030A, but they were designed for other uses. Whether one suits a structured-light or flood projector has to be checked case by case with our design team.
CUSTOMER SCENARIO
A module maker sells one stereo camera to a dozen robot builders and wants one lens that every integrator can mount the same way. Question to ask: how much lens-to-lens variation can your stereo calibration absorb, and what does it cost in yield if the lens drifts?
Which lens families show up in which markets?
The same lens often serves several markets, for different reasons. The matrix shows where each family tends to land. It is illustrative, not a selection tool.
Table 2: Illustrative lens-family matrix
| Lens family | Humanoids & Cobots | Mobile Robots & Drones | Industrial Automation | Depth Sensing & AI |
|---|---|---|---|---|
| Ultra-wide / fisheye | Torso surround | Surround perception, SLAM | - | - |
| Low-distortion wide | Wrist and hand | Forward navigation | Embedded and AGV cameras | - |
| NIR / ToF | Head depth module | Dark aisles | 3D vision | Core fit |
| Ruggedized / sealed | - | Dust, washdown, outdoor | Factory floor | - |
| Fast, higher-resolution | Head cameras | - | Smart cameras | Stereo pairs |
| Projection | - | - | - | Emitter side [CONFIRM] |
The lens count per robot matters as much as the lens type. A lens that is one line item on a smart camera is six to twelve on a humanoid, and any lens-to-lens variation is multiplied the same way. Table 3 lists the counts we use as working figures.
Table 3: Camera count by robot type
| Robot type | Typical cameras |
|---|---|
| Humanoid | About 6 to 12 (published designs) |
| Collaborative arm / guided cell | 1 to 2 |
| Warehouse AMR | About 3 [CONFIRM] |
| Service robot | 2 to 4 |
| Drone | About 6 navigation cameras plus payload (published designs) |
| Smart camera | 1 lens per camera |
| Depth module | 2 to 3 lenses |
What should you bring to your first conversation with a Sunex engineer?
These eight items let an engineer recommend a starting lens in one conversation, not three.
- Sensor part number, size and pixel pitch, and whether it is global or rolling shutter.
- Field of view needed, horizontal and diagonal, and how much distortion your software can correct.
- Number of cameras per robot and how many robots you expect to build in a year.
- Wavelengths in use: visible only, NIR, or an active emitter, and its wavelength.
- Environment: dust, washdown, outdoor sun, vibration, temperature range.
- Mechanical limits: housing size, mount style, thread, weight.
- Stereo or paired cameras, and how closely the pair needs to match.
- Schedule and verification: when you need first images and what testing the lens must pass.
Examples in this article are not prescriptions. The right lens depends on your sensor, your environment and your test results.
What is the fastest way to a first lens recommendation?
- Talk to a Sunex optical engineer about your sensor and field of view: sunex.com/contact/
- Browse the lens portfolio by family. sunex.com/products/
- Watch the video library on distortion, depth-sensing and NIR coatings. youtube.com/@sunexinc